Xiaomi Roborock LIDAR: Difference between revisions
Jump to navigation
Jump to search
No edit summary |
Categorisation per 2026-09 category review |
||
| Line 37: | Line 37: | ||
==Additional/Novel Uses== | ==Additional/Novel Uses== | ||
To be completed | To be completed | ||
[[Category:LIDAR]] | |||
[[Category:Teardowns]] | |||
Latest revision as of 14:43, 29 September 2026

LIDAR from the Xiaomi robotic vacuum, very similar in design to the one used in the Neato XV-11.
Teardown Video
5 minute video showing all the parts of the LIDAR and how they go together, helps to understand all the parts and pieces pictured below.
PCB Pictures
-
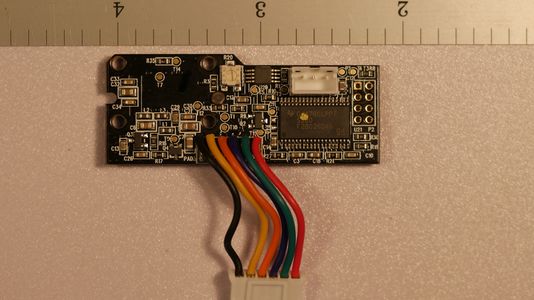 LIDAR CMOS sensor and DSP board - top side
-
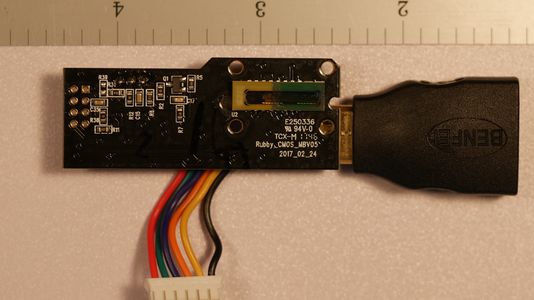 LIDAR CMOS sensor and DSP board - bottom side (BENFEI connector to balance board for picture)
-
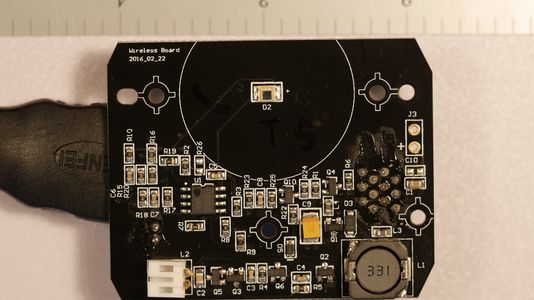 Wireless receiver board - top
-
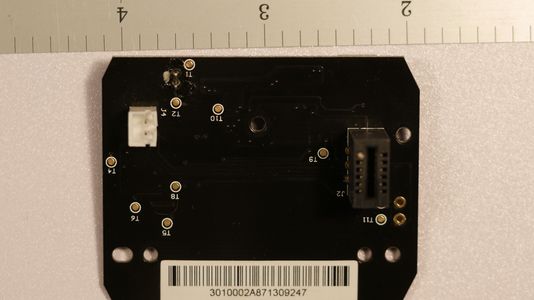 Wireless receiver board - bottom
-
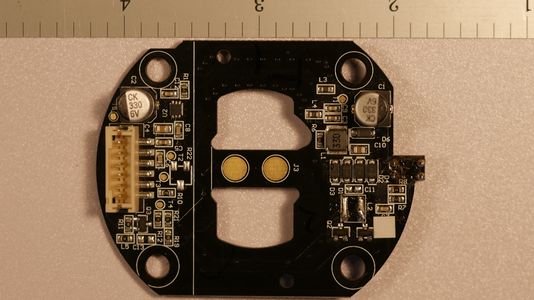 Power board - top
-
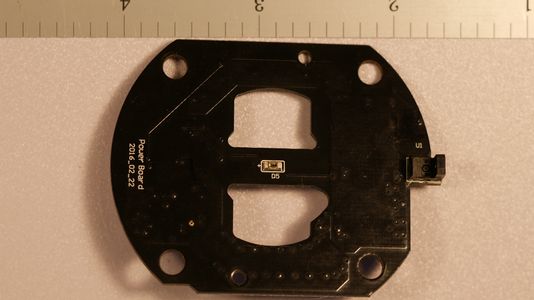 Power board - bottom
-
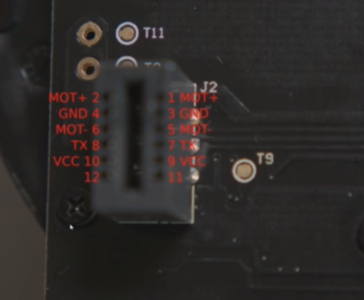 Pinout of connector on Power Board that connects to Roborock S5


Mechanical Pictures
-
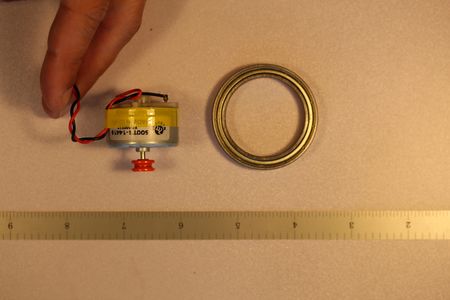 DC Motor and Bearing
-
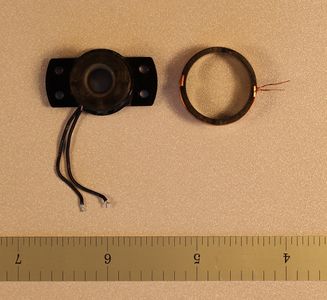 Inductors used for wireless power
-
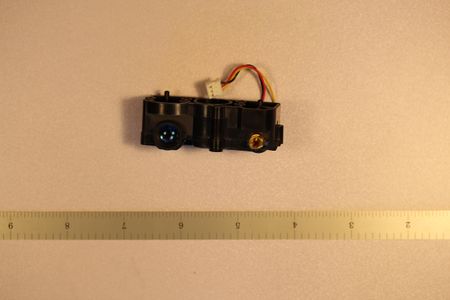 Laser and Lens housing module, CMOS sensor board mounts to this
-
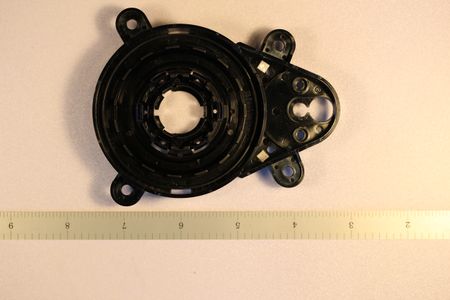 Base housing - top
-
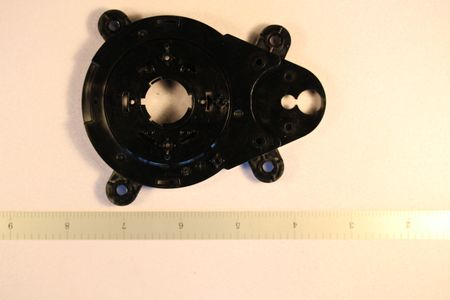 Base housing - bottom
-
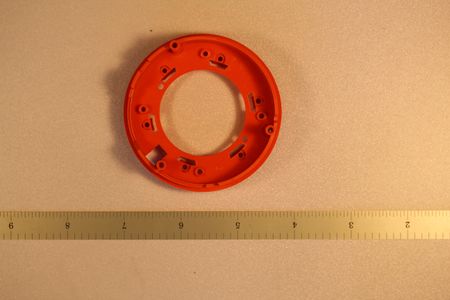 Rotating housing - top
-
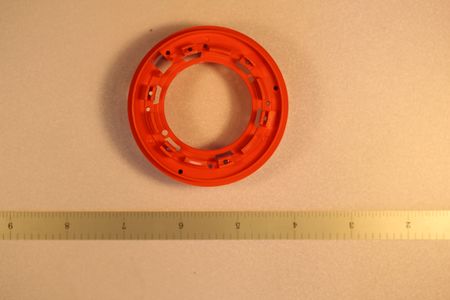 Rotating housing - bottom
-
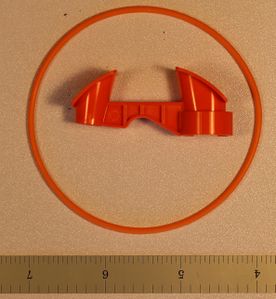 Belt and lens/laser hood


Analysis of Hardware
To be completed
Additional/Novel Uses
To be completed